Overview
Notation
$$ \begin{aligned} &\Theta &&: \text{Joint velocities} \cr &\Theta_{a/p} &&: \text{Active/Passive} \cr &W &&: \text{Twist} \cr &V &&: \text{Velocity of end-effector} \cr & \Omega &&: \text{Angular Velocity} \cr & X &&: \text{Generalized coordinates} \end{aligned} $$
Outline
Inverse Kinematics : Relates position
Inverse Jacobian : Relates velocities (in generalized coordinates)
Inverse Kinematic Jacobian : Relates velocities (in cartesian coordinates)
Inverse Kinematics
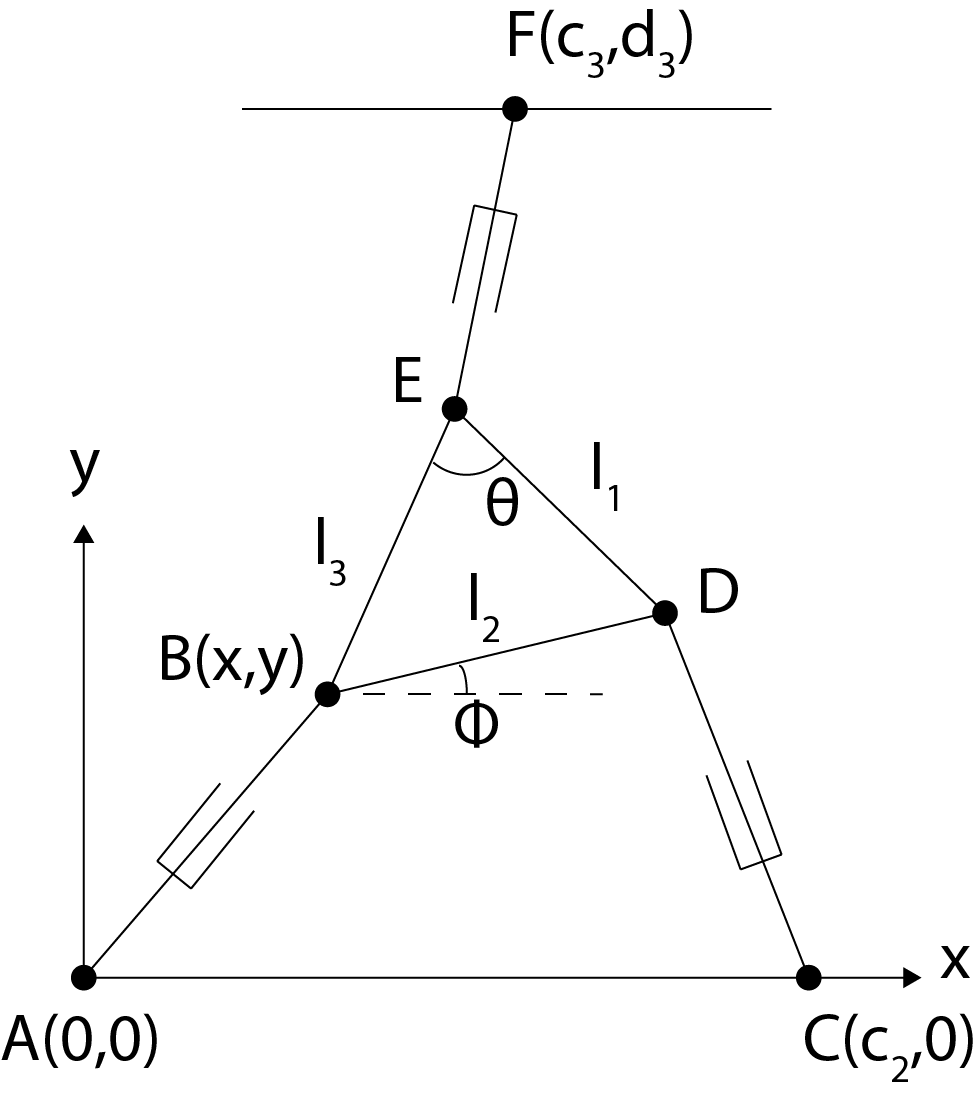
Inverse kinematics are a way of getting joint coordinates from a desired end-effector pose. For a $3{\text -}RPR$ planar robot it is given by
$$ \begin{cases} \rho_1^2 = &x^2 + y^2 \cr \rho_2^2 = &(x+l_2 \cos({\Phi}) - c_2)^2 + (y+l_2 \sin({\Phi}))^2 \cr \rho_2^2 = &(x+l_3 \cos({\Phi + \theta}) - c_3)^2 + (y+l_3 \sin({\Phi + \theta}) - d_3)^2 \end{cases} $$
Inverse Jacobian
The joint coordinates and generalized coordinates are related by
$$ A \dot\bold \Theta_a + B\dot\bold X + C \dot\bold \Theta_p = 0 $$
For the minimal kinematic set (MKS), where the joint velocities $\dot X$ are reduced to the active joints $\dot \Theta_a$ , we can ignore $\dot \Theta_p$ and get
$$ A \dot \bold \Theta_a + B \dot \bold X = 0 $$
If $B^{-1}A$ is invertible,
$$ \dot \Theta_a = \underbrace{-A^{-1} B}_{J^{-1}}\ \dot\bold X $$
The inverse jacobian is given by
$$ J^{-1} = -A^{-1}B $$
Inverse Kinematic Jacobian
The inverse kinematic jacobian $J_k^{-1}$ relates joint velocities to end-effector velocities. For the MKS
$$ A \dot \bold \Theta_a + B \ \underbrace{ H^{-1} \bold W }_{\dot\bold X} = 0 $$
$J_k$ is a transformation from generalized coordinates to cartesian twist.
The inverse kinematic jacobian is therefore
$$ \begin{aligned} J_k^{-1} &= -A^{-1} B H^{-1} \cr &= \enskip J^{-1} H^{-1} \end{aligned} $$
Acceleration Analysis
Directly by differentiating
$$ \dot \bold \Theta = J_K^{-1} \bold W $$
to get
$$ \ddot \Theta = J_k^{-1} \dot \bold W + \dot J_K^{-1} \bold W $$
Summary
Inverse Kinematic
$$ \begin{cases} \rho_1^2 = &x^2 + y^2 \cr \rho_2^2 = &(x+l_2 \cos({\Phi}) - c_2)^2 + (y+l_2 \sin({\Phi}))^2 \cr \rho_2^2 = &(x+l_3 \cos({\Phi + \theta}) - c_3)^2 + (y+l_3 \sin({\Phi + \theta}) - d_3)^2 \end{cases} $$
Inverse Kinematic Jacobian
$$ \begin{aligned} J_k^{-1} &= -A^{-1} B H^{-1} \cr &= \ \ \ J^{-1} H^{-1} \end{aligned} $$
Acceleration
$$ \ddot \Theta = J_k^{-1} \dot \bold W + \dot J_K^{-1} \bold W $$